RoboCasa365
RoboCasa365 tests a Franka Panda on a mobile base in simulated kitchens, with a language instruction for each task. Behind the scenes, Manifold runs robocasa/robocasa v1.0.
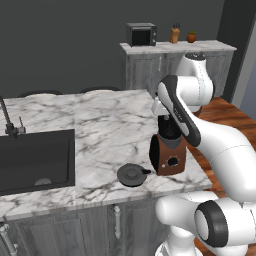
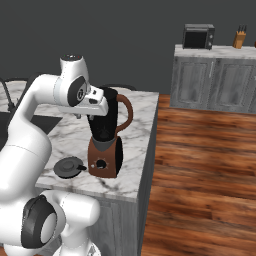
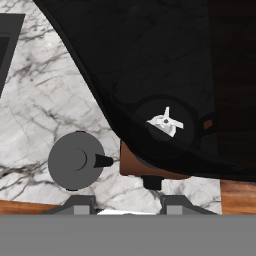
Manifold runs the three task sets of RoboCasa's multitask learning benchmark. Every episode samples its kitchen and objects from RoboCasa's pretrain split.
robocasa365-atomic-seenruns short tasks with a single skill, such as opening a drawerrobocasa365-composite-seenruns tasks that chain several skills, from the pretraining task setrobocasa365-composite-unseenruns composite tasks that are not in the pretraining task set
| Benchmark | Tasks | Episodes per task | Total episodes |
|---|---|---|---|
robocasa365-atomic-seen | 18 | 50 | 900 |
robocasa365-composite-seen | 16 | 50 | 800 |
robocasa365-composite-unseen | 16 | 50 | 800 |
Contract
Observation
Each step, the benchmark sends an observation with these fields. If Manifold has adapters for the difference, it converts the observation to the form that your policy signature declares. Then it passes the observation to your policy.
| Field | Values | Meaning |
|---|---|---|
state["ee_pose"] | x, y, z | end effector position relative to the robot's base, in meters |
| qx, qy, qz, qw | end effector rotation relative to the robot's base, as a quaternion, scalar last | |
| f0, f1 | finger joint positions in meters; the second finger's value is negative | |
state["base_pose"] | x, y, z | base position in the world, in meters |
| qx, qy, qz, qw | base rotation in the world, as a quaternion, scalar last | |
instruction | the task prompt, a string | |
sensors["agentview_left"] | 256x256 color image, uint8, upright | |
sensors["agentview_right"] | 256x256 color image, uint8, upright | |
sensors["wrist"] | 256x256 color image, uint8, upright |
The benchmark sends no depth images and no camera calibration.
Action
The benchmark accepts 12 values per step, in this order.
| Index | Values | Meaning |
|---|---|---|
| 0 to 2 | dx, dy, dz | end effector position change, in the robot base's frame |
| 3 to 5 | rx, ry, rz | end effector rotation change, axis-angle, in radians |
| 6 | gripper | below 0.5 opens the gripper, 0.5 and above closes it |
| 7 to 9 | vx, vy, vyaw | mobile base velocity, in the robot base's frame |
| 10 | torso | torso height change |
| 11 | mode | below 0.5 applies the arm's change to its measured pose, 0.5 and above applies it to its previous target, so the arm keeps up with the moving base |
Return actions in the exact format that your policy signature declares. Manifold will attempt to convert your policy's output to match what the benchmark accepts.
Compatible policy signatures
Change the values to match your policy. If the policy signature below matches what your policy natively requires, then it is guaranteed to be compatible with RoboCasa365.
Show policy signature
POLICY_SIGNATURE = PolicySignature(
    action_space=CompositeActionSpace(
        groups=(
            EEActionSpace(
                rotation=RotationFormat.AXIS_ANGLE,
                gripper=GripperFormat.SIGNED_OPEN_LOW,
                frame=Frame.BASE,
                delta=True,
            ),
            BodyActionSpace(
                part=BodyPart.MOBILE_BASE,
                dof=3,
                command=Command.VELOCITY,
                frame=Frame.BASE,
            ),
            BodyActionSpace(part=BodyPart.TORSO, dof=1, command=Command.DELTA),
        ),
        mode_slot=ModeCut.BINARY_0_5,
    ),
    proprioception=Proprioception(
        ee_pose=EEObservationSpec(
            rotation=RotationFormat.QUATERNION,
            gripper=GripperObservationSpec(dim=2),
            frame=Frame.BASE,
        ),
        base_pose=EEObservationSpec(rotation=RotationFormat.QUATERNION, frame=Frame.WORLD),
    ),
    cameras=(
        Camera(
            name="agentview_left",
            shape=(256, 256, 3),
            mount=Mount.SCENE,
            orientation=CameraOrientation.UPRIGHT,
        ),
        Camera(
            name="agentview_right",
            shape=(256, 256, 3),
            mount=Mount.SCENE,
            orientation=CameraOrientation.UPRIGHT,
        ),
        Camera(
            name="wrist",
            shape=(256, 256, 3),
            mount=Mount.WRIST,
            orientation=CameraOrientation.UPRIGHT,
        ),
    ),
    instruction=True,
)
Debugging and testing
- The gripper and motion mode values have a threshold of 0.5. A policy that expects a threshold value of 0 can misbehave. For example, if it outputs 0.3 to close the gripper, the gripper opens instead.
- Observation quaternions are scalar last (x, y, z, w). Check the order your rotation library uses before converting.
To check your policy end to end before a full run, submit it against debug-robocasa365, which runs the first atomic task, CloseBlenderLid, for 2 episodes.
For the full walkthrough, see Serve your policy.